
Classification, Composition and Development Trend of Injection Molding Manipulator
Release time:
2019-05-23
Manipulator is an automated device that can imitate the basic movements of human hands and arms to grab, carry items or operate tools with a fixed program. In recent years, China's plastic injection molding industry has developed rapidly, but the penetration rate of injection molding robots in the domestic plastic machine industry is less than 10%; now, especially in South China and East China, plastic processing plants have shown a strong interest in injection molding robots!
1. what is the injection molding manipulator?
Manipulator is an automated device that can imitate the basic movements of human hands and arms to grab, carry items or operate tools with a fixed program.
Injection molding manipulator, as the name implies is the auxiliary injection molding machine, help injection molding machine to achieve injection molding, grab the integration of a class of manipulator. In recent years, China's plastic injection molding industry has developed rapidly, but the penetration rate of injection molding robots in the domestic plastic machine industry is less than 10%; now, especially in South China and East China, plastic processing plants have shown a strong interest in injection molding robots!
Classification of 2. injection molding manipulator
In the injection molding industry, we are generally divided into two categories according to the degree of intelligence:
1. Basic injection molding manipulator: This type of manipulator includes a fixed mode program and a teaching mode program modulated according to the production process. The fixed pattern program includes several standard processes of the injection molding process, making simple, regular, and repetitive actions. The teaching mode program is designed for injection molding machines with special processes, and the requirements of some complex actions are achieved by arranging the standard process actions in an orderly manner.
2, intelligent injection molding manipulator: this type of manipulator includes any point standby, multi-point memory placement and multi-degree of freedom and other functions, through the use of servo motor drive, can maximize the imitation of human hands and arms to complete complex movements. At the same time, some are also equipped with advanced sensors, so that the manipulator has a tactile, visual and even thermal function, which has a further intelligent.
Composition of 3. injection molding manipulator
The injection molding manipulator generally consists of three parts: the execution system, the drive system and the control system. The execution system, like our hands, completes the set action; the drive system, like our muscles, provides power for the execution system; the control system, like our brain, sends instructions to the execution system.
The specific signal transmission process is as follows:

The operator operates on the man-machine interface or the control system issues instructions in the automatic mode. After the injection molding machine opens the mold, the information is transmitted to the manipulator. After the manipulator receives the information, it first cuts off the closing signal of the injection molding machine (to ensure the safety of the manipulator when taking goods), and then carries out the taking action. After completing the taking action, send the information to the injection molding machine and the injection molding machine mold.
4. injection molding manipulator function
The competition in injection molding is becoming increasingly fierce, and the quality and efficiency of molding are related to the survival of enterprises. The molding quality is related to the performance of the injection molding machine itself, the mold process and the surrounding environment, and the molding efficiency is related to the mold precision, the molding process and the production quantity. With the increasing supply of injection molding machine operators and the increase of manual production costs, the removal manipulator of injection molding machine is also widely used. The application of plastic molding automation is extremely common, and the manipulator mainly shows the following uses in the application process:
1. The manipulator takes out the in-mold products and replaces people to turn the original semi-automatic production to fully automated production;
2. Take out the product from the mechanical hand mold, and embed the product in the mold (label, embedded metal, secondary molding, etc.);
3. Automatic packaging and storage after the manipulator is taken out;
4. Forming raw material automatic feeding system, waste recycling system;
5, the whole plant production control system and so on;
Because the molding products are different, the application of automation is also very complicated because it can replace the low efficiency of manpower and ensure the molding product process is more and more widely used. Injection molding machine take out manipulator is the most widely used in molding automation.
Development Trend of 5. Injection Molding Manipulator
At present, the application of injection molding manipulator is expanding, and the technical performance is constantly improving. The current development trend is:
1. Multi-function: In the past, it can only complete the function of taking parts, but now it can realize functions such as arrangement, stacking, embedding, shearing, detection, etc.
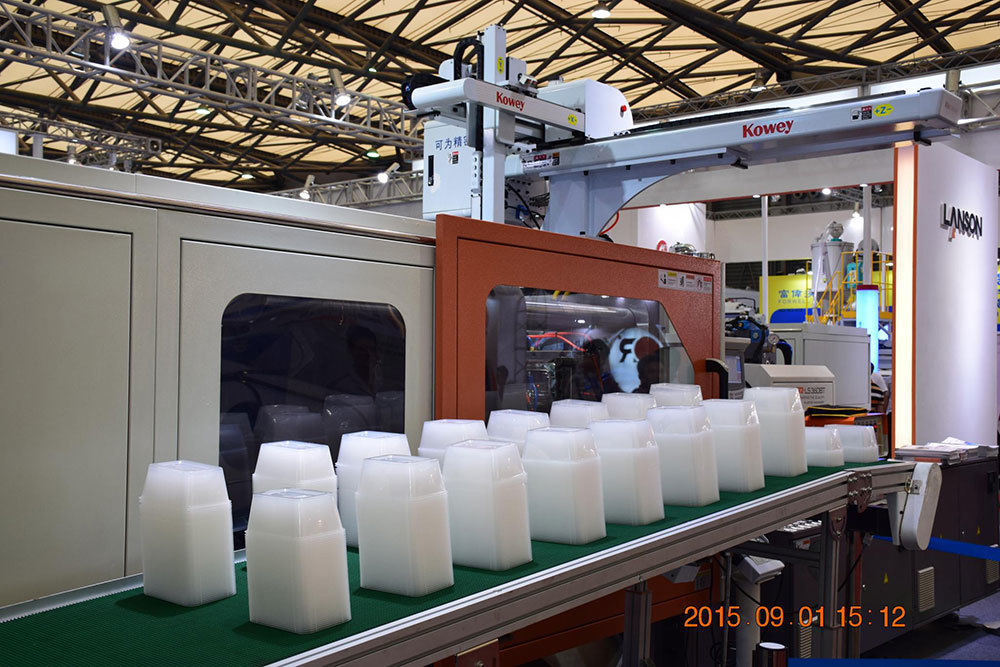
2. Combination: In the application of high requirements, it Kowey coordinated by using multiple manipulators. For example, Xiaobian saw a company in the 2015 rubber and plastic exhibition through the coordination and cooperation of three manipulators to take out and put various products into a set box in an orderly manner.
3, tactile, visual: injection molding products, generally need manual inspection, in order to avoid defective products packaging. Using image processing technology, let the robot instead of manual inspection, thus saving labor costs.
4, intelligent (self-adjustment): have a certain perception ability (sensor), through the perception of changes in external conditions, and make corresponding adjustments. For example: with the mechanical wear and the loosening of the joint parts, the movement of the manipulator position may have a small deviation, the future of the manipulator may have the ability to adjust, so as to ensure the accuracy.
Share

Address
No. 830, East Jinhai Avenue, Sanzao Town, Jinwan District, Zhuhai City, Guangdong Province
Tiktok
Video Number
WeChat Public Number
Mobile phone end
对不起,当前栏目暂无内容
您可以查看其他栏目
Sorry, there is currently no content in the current column
You can check other sections
营业执照
Business License